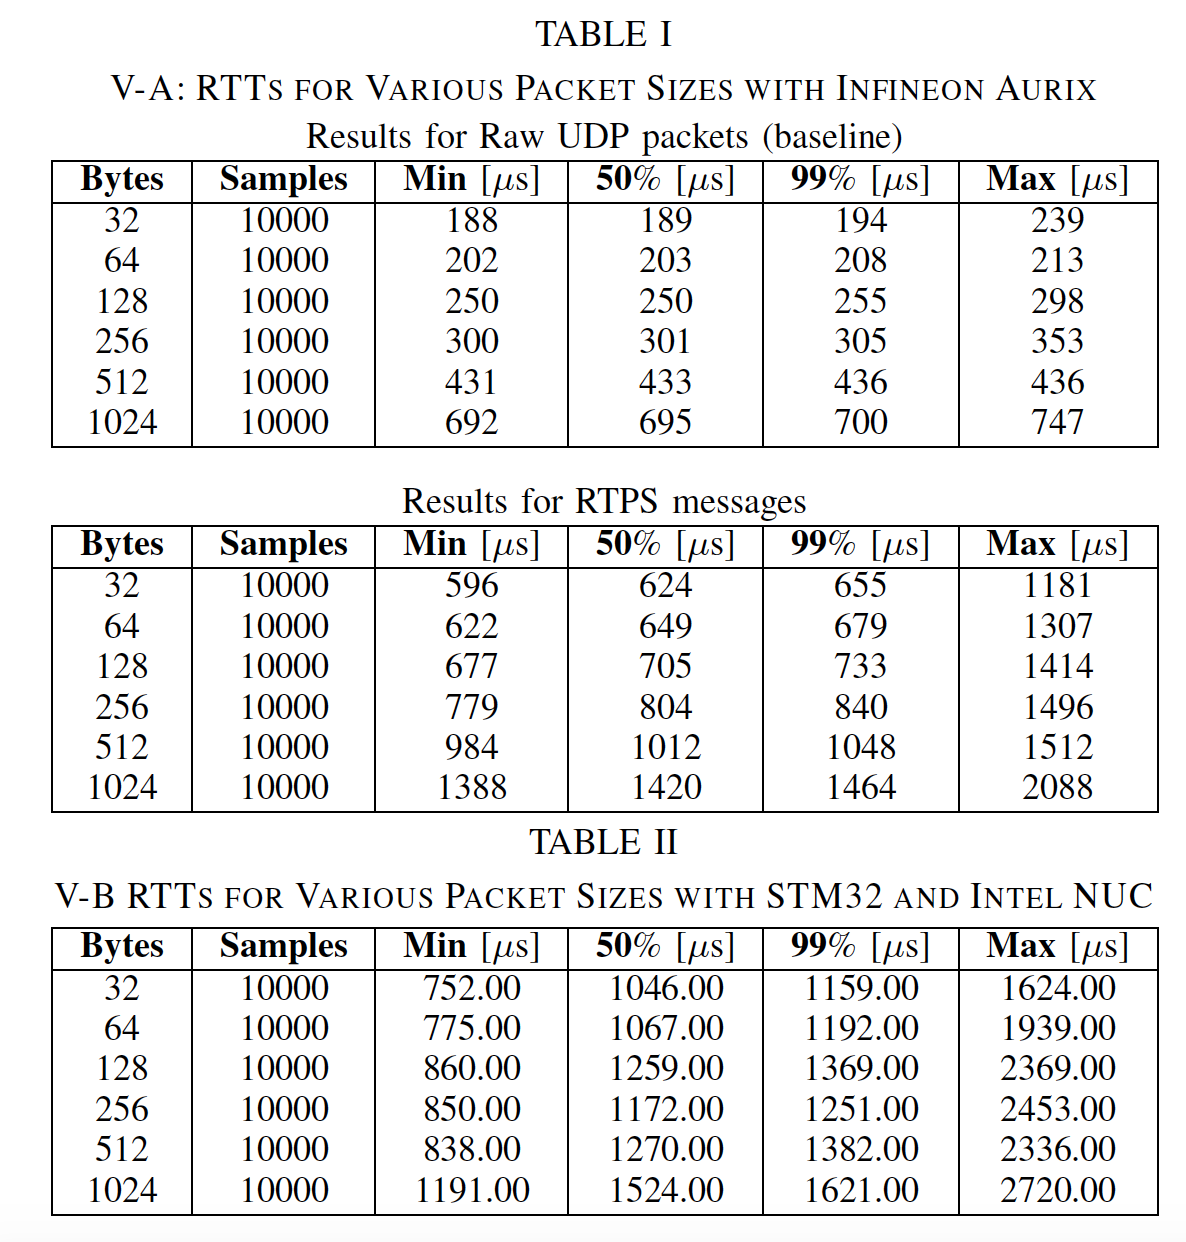
# embeddedRTPS **Repository Path**: syfchao/embeddedRTPS ## Basic Information - **Project Name**: embeddedRTPS - **Description**: Portable implementation of the RTPS/DDS protocol for embedded devices. - **Primary Language**: Unknown - **License**: Not specified - **Default Branch**: master - **Homepage**: None - **GVP Project**: No ## Statistics - **Stars**: 0 - **Forks**: 0 - **Created**: 2026-09-08 - **Last Updated**: 2026-09-08 ## Categories & Tags **Categories**: Uncategorized **Tags**: None ## README # embeddedRTPS This repository contains source code for embeddedRTPS, a portable and open-source C++ implementation of the Real-Time Publish-Subscribe Protocol (RTPS) for embedded system. RTPS is based on the publish-subscribe mechanism and is at the core of the Data Distribution Service (DDS). DDS is used, among many other applications, in Robot Operating System 2 (ROS2) and is also part of the AUTOSAR Adaptive platform. embeddedRTPS allows to integrate Ethernet-capable microcontrollers into DDS-based systems as first-class participants. embeddedRTPS is portable, as it only consumes lightweightIP and FreeRTOS APIs, which are available for a large number of embedded systems. embeddedRTPS avoids dynamic memory allocation once endpoints are constructed possible. Please note that embeddedRTPS only implements rudimentary Quality-of-Service (QoS) policies and is far from a complete RTPS implementation. More information is provided in our ITSC'2019 publication [1], which we kindly ask you to consider citing if you find embeddedRTPS helpful for your work. ### Features **Discovery** Simple Participant Discovery Protocol (SPDP) as well as Simple Endpoint Discovery Protocol (SEDP) are implemented. **Interoperability** We have sucessfully tested interoperability with **FastDDS 2.3.1** **QoS Policies** Both reliable as well as best-effort endpoints are implemented. **UDP Multicast** Our implementation supports multicast locators. **Message Size** Message size is currently limited by lwIP buffer size and are not split up among multiple buffers ### Supported Platforms We have successfully ported embeddedRTPS on the following platforms: - Infineon Aurix - Xilinx UltraScale+ Cortex R5 - STM32F767ZI Due to license issues, we can only make source code available for the STM32. ### Examples The following repository provides code examples for running embeddedRTPS on the STM32F767ZI - [STM32F767ZI](https://github.com/embedded-software-laboratory/embeddedRTPS-STM32) #### Runnig on Linux & Unittests The following repository allow to compile and run embeddedRTPS on Linux for development purposes. This repository also contains unittests for embeddedRTPS. - [embeddedRTPS-linux](https://github.com/embedded-software-laboratory/embeddedRTPS-Linux) ### Third Party Libraries embeddedRTPS makes use of the following third party libraries: - lwIP (Raw Mode) - FreeRTOS - [eProsima Micro-CDR](https://github.com/eProsima/Micro-CDR) ### Performance Round-trip-times (RTT) for different platforms and packet sizes are depicted in the tables below. **Table 1** 2x Infineon Aurix TC277 running embeddedRTPS. **Table 2** STM32F7 running embeddedRTPS connected to an Intel NUC running eProsima FastRTPS 1.8.0. ### Acknowledgment embeddedRTPS has been developed at **[i11 - Embedded Software, RWTH Aachen University](https://www.embedded.rwth-aachen.de)** in the context of the **[UNICARagil](https://www.unicaragil.de/en/)** project. *This research is accomplished within the project “UNICARagil” (FKZ EM2ADIS002). We acknowledge the financial support for the project by the Federal Ministry of Education and Research of Germany (BMBF).* ### References
[1] A. Kampmann, A. Wüstenberg, B. Alrifaee and S. Kowalewski, "A Portable Implementation of the Real-Time Publish-Subscribe Protocol for Microcontrollers in Distributed Robotic Applications," 2019 IEEE Intelligent Transportation Systems Conference (ITSC), Auckland, New Zealand, 2019, pp. 443-448. doi: 10.1109/ITSC.2019.8916835

``` @INPROCEEDINGS{8916835, author={A. {Kampmann} and A. {Wüstenberg} and B. {Alrifaee} and S. {Kowalewski}}, booktitle={2019 IEEE Intelligent Transportation Systems Conference (ITSC)}, title={A Portable Implementation of the Real-Time Publish-Subscribe Protocol for Microcontrollers in Distributed Robotic Applications}, year={2019}, volume={}, number={}, pages={443-448}, keywords={automobiles;intelligent transportation systems;microcontrollers;middleware;operating systems (computers);protocols;robot programming;Robot Operating System 2;microcontrollers;distributed automotive applications;distributed robotic applications;Data Distribution Service;DDS;open-source RTPS implementations;publish-subscribe protocol;AUTOSAR Adaptive platform;Protocols;Automotive engineering;Message systems;Real-time systems;Microcontrollers;Middleware;Operating systems}, doi={10.1109/ITSC.2019.8916835}, ISSN={null}, month={Oct},} ```